Ph.D. Student, Purdue ECE

Juntong Peng 彭钧桐

Autonomous driving Multi-agent intelligence Foundation model

My Background.

Hi! I am a third-year Ph.D. student in Purdue ECE, co-advised by Prof. Yaobin Chen and Prof. Ziran Wang.

I received my bachelor degree in information engineering from Shanghai Jiao Tong University, advised by Prof. Siheng Chen. I have also spent a wonderful summer at the Department of Computer Science, Purdue University as a research intern, advised by Prof. Aniket Bera.

My research focuses on autonomous driving and computer vision, with an emphasis on multi-agent intelligence, vision-language-action (VLA) models, and foundation models for embodied autonomy. I am broadly interested in building efficient, trustworthy, and human-aligned autonomous systems that can perceive, reason, collaborate, and act in complex real-world environments.

Lately.

Aug 31, 2026 VLM-DC: Vision Language Model for Automotive Data Collection was accepted for publication in the IEEE Internet of Things Journal.
Jul 13, 2026 Four papers were accepted to IROS 2026: FleetAgent, OmniV2X, ViLaD, and Efficient and Explainable End-to-End Autonomous Driving via Masked Vision-Language-Action Diffusion.
Jul 13, 2026 QuantV2X: A Fully Quantized Multi-Agent System for Cooperative Perception was accepted to ECCV 2026.

Perceive. Collaborate. Act.

All publications
  1. IEEE IoT J.
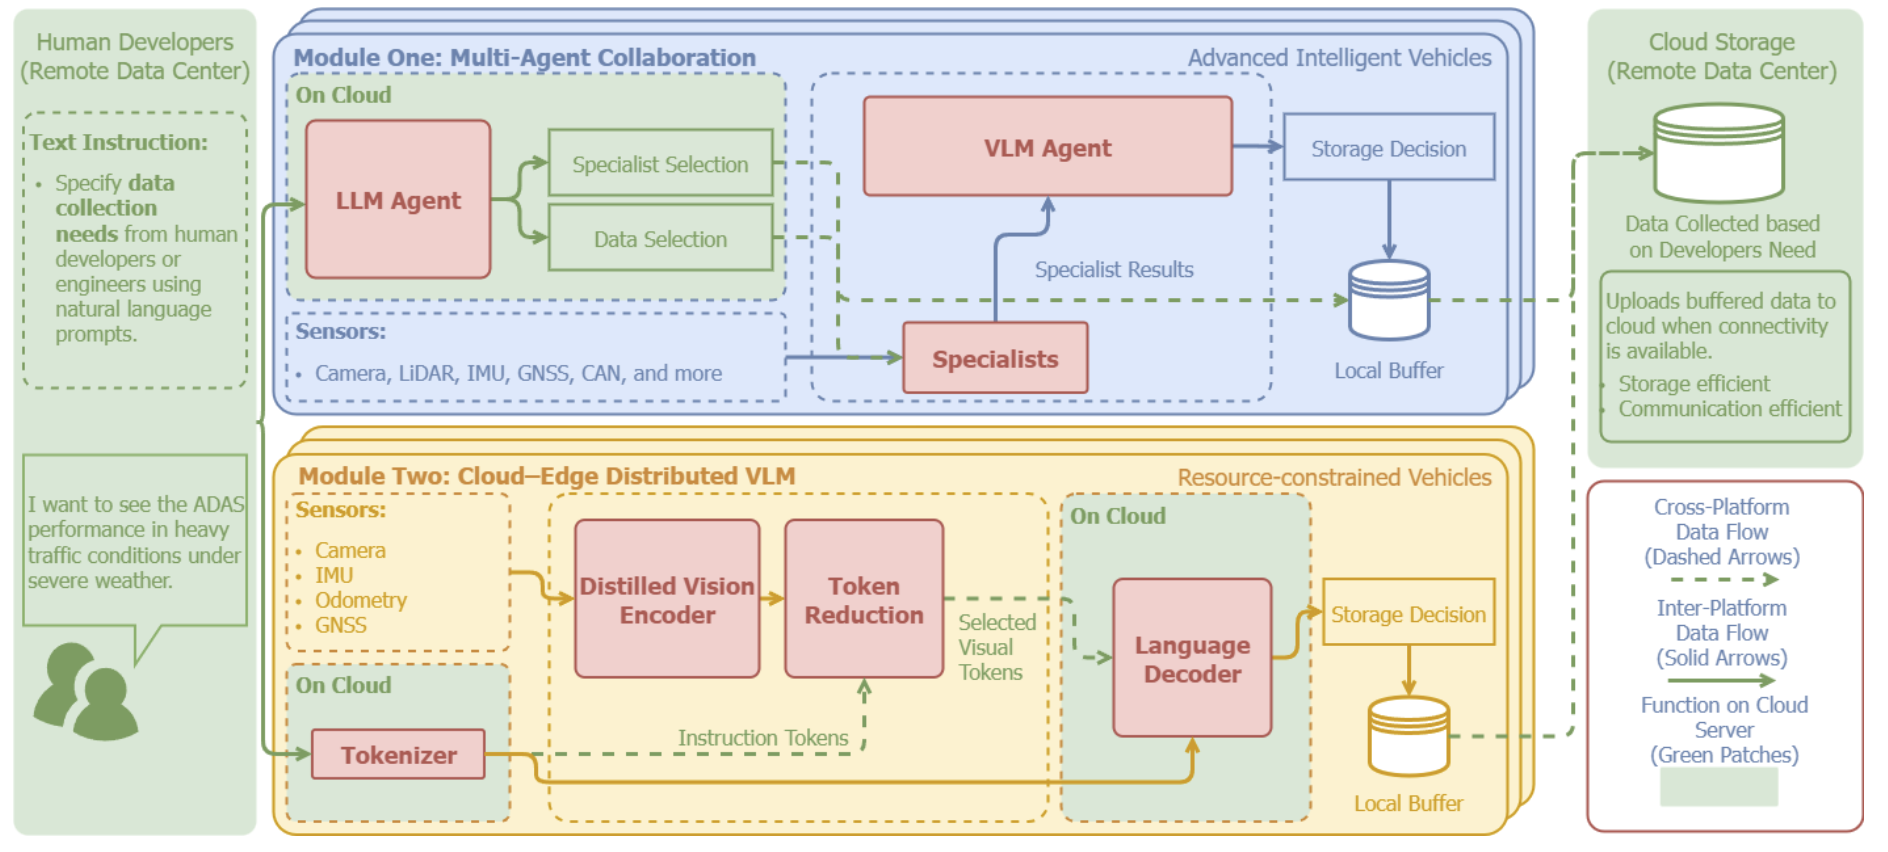
    VLM-DC framework: multi-agent collaboration and cloud-edge distributed VLM modules for targeted automotive data collection
    VLM-DC: Vision Language Model for Automotive Data Collection
    Can Cui*, Juntong Peng*, Sungyeon Park, Yongkang Liu, Seyhan Ucar, Satoshi Kitai, Ahmadreza Moradipari, Maryam Khabazi, and Ziran Wang
    * Equal contribution.
    IEEE Internet of Things Journal, 2026
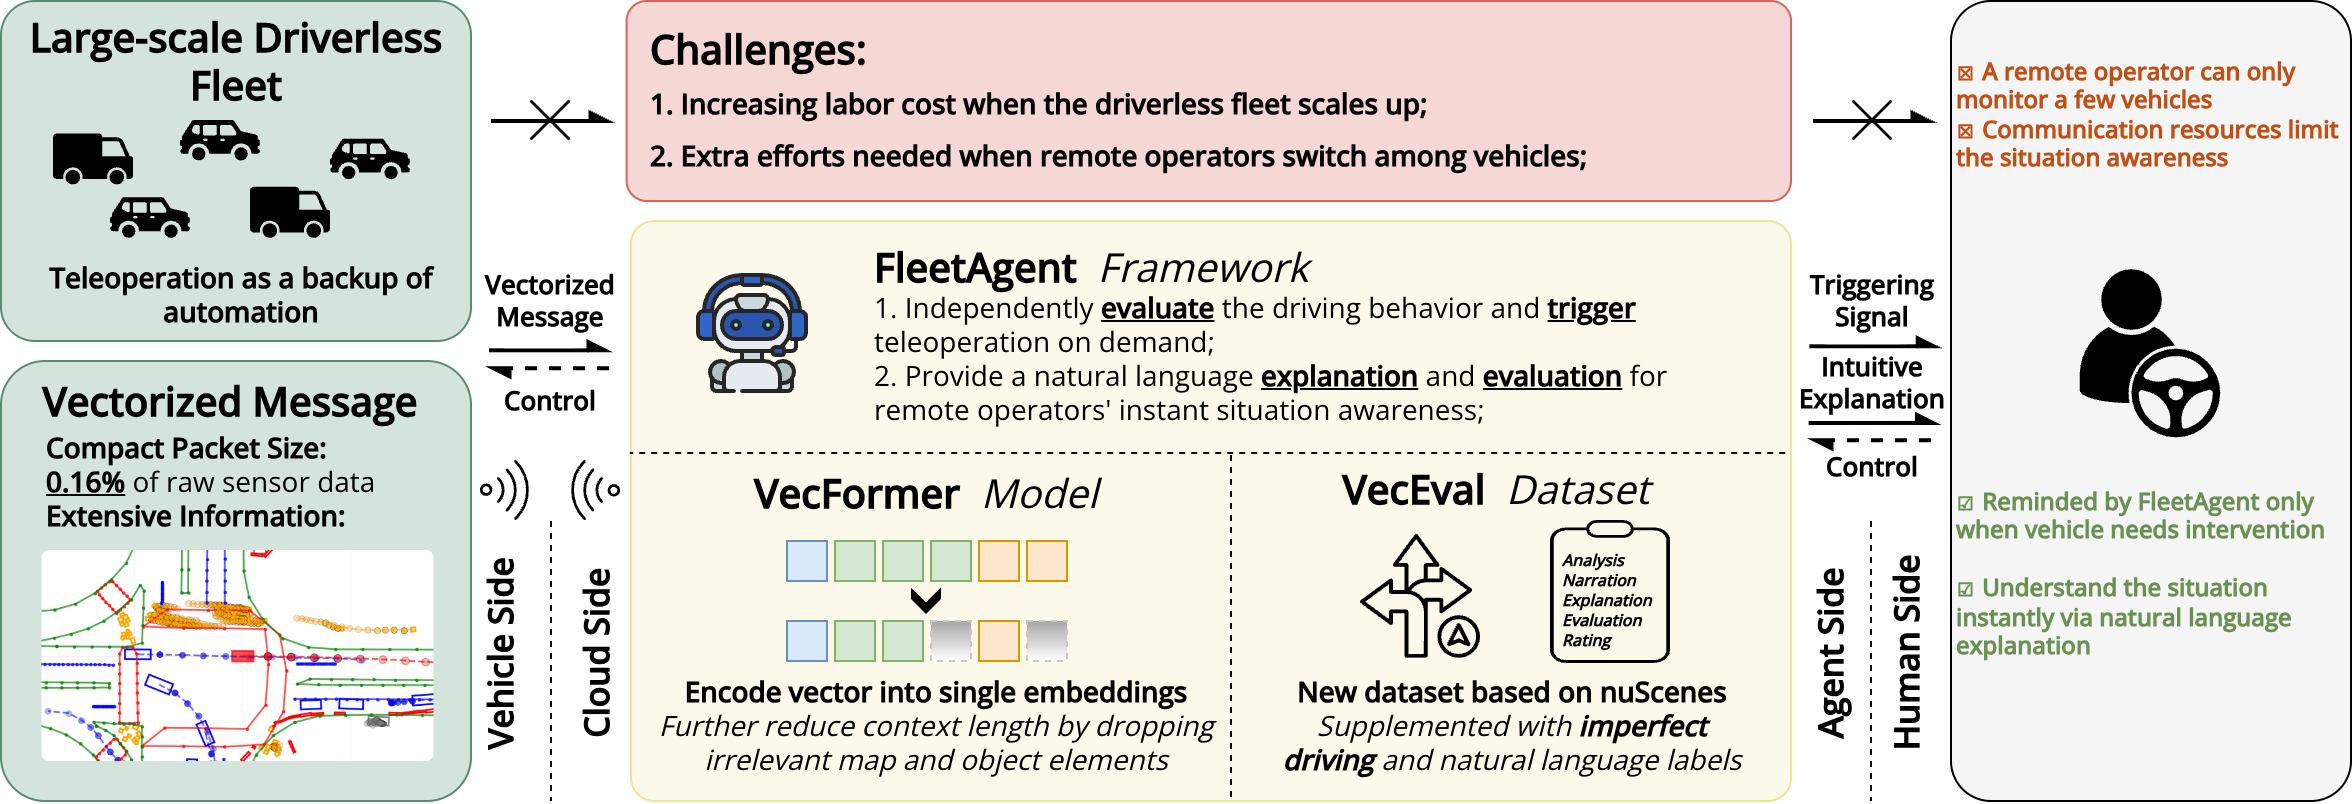
  2. FleetAgent: Teleoperation Assistant for Autonomous Fleets via Vectorized V2N Messages
    Juntong Peng, Qi Chen, Deyuan Qu, Takayuki Shimizu, Yaobin Chen, and Ziran Wang
    In 2026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026
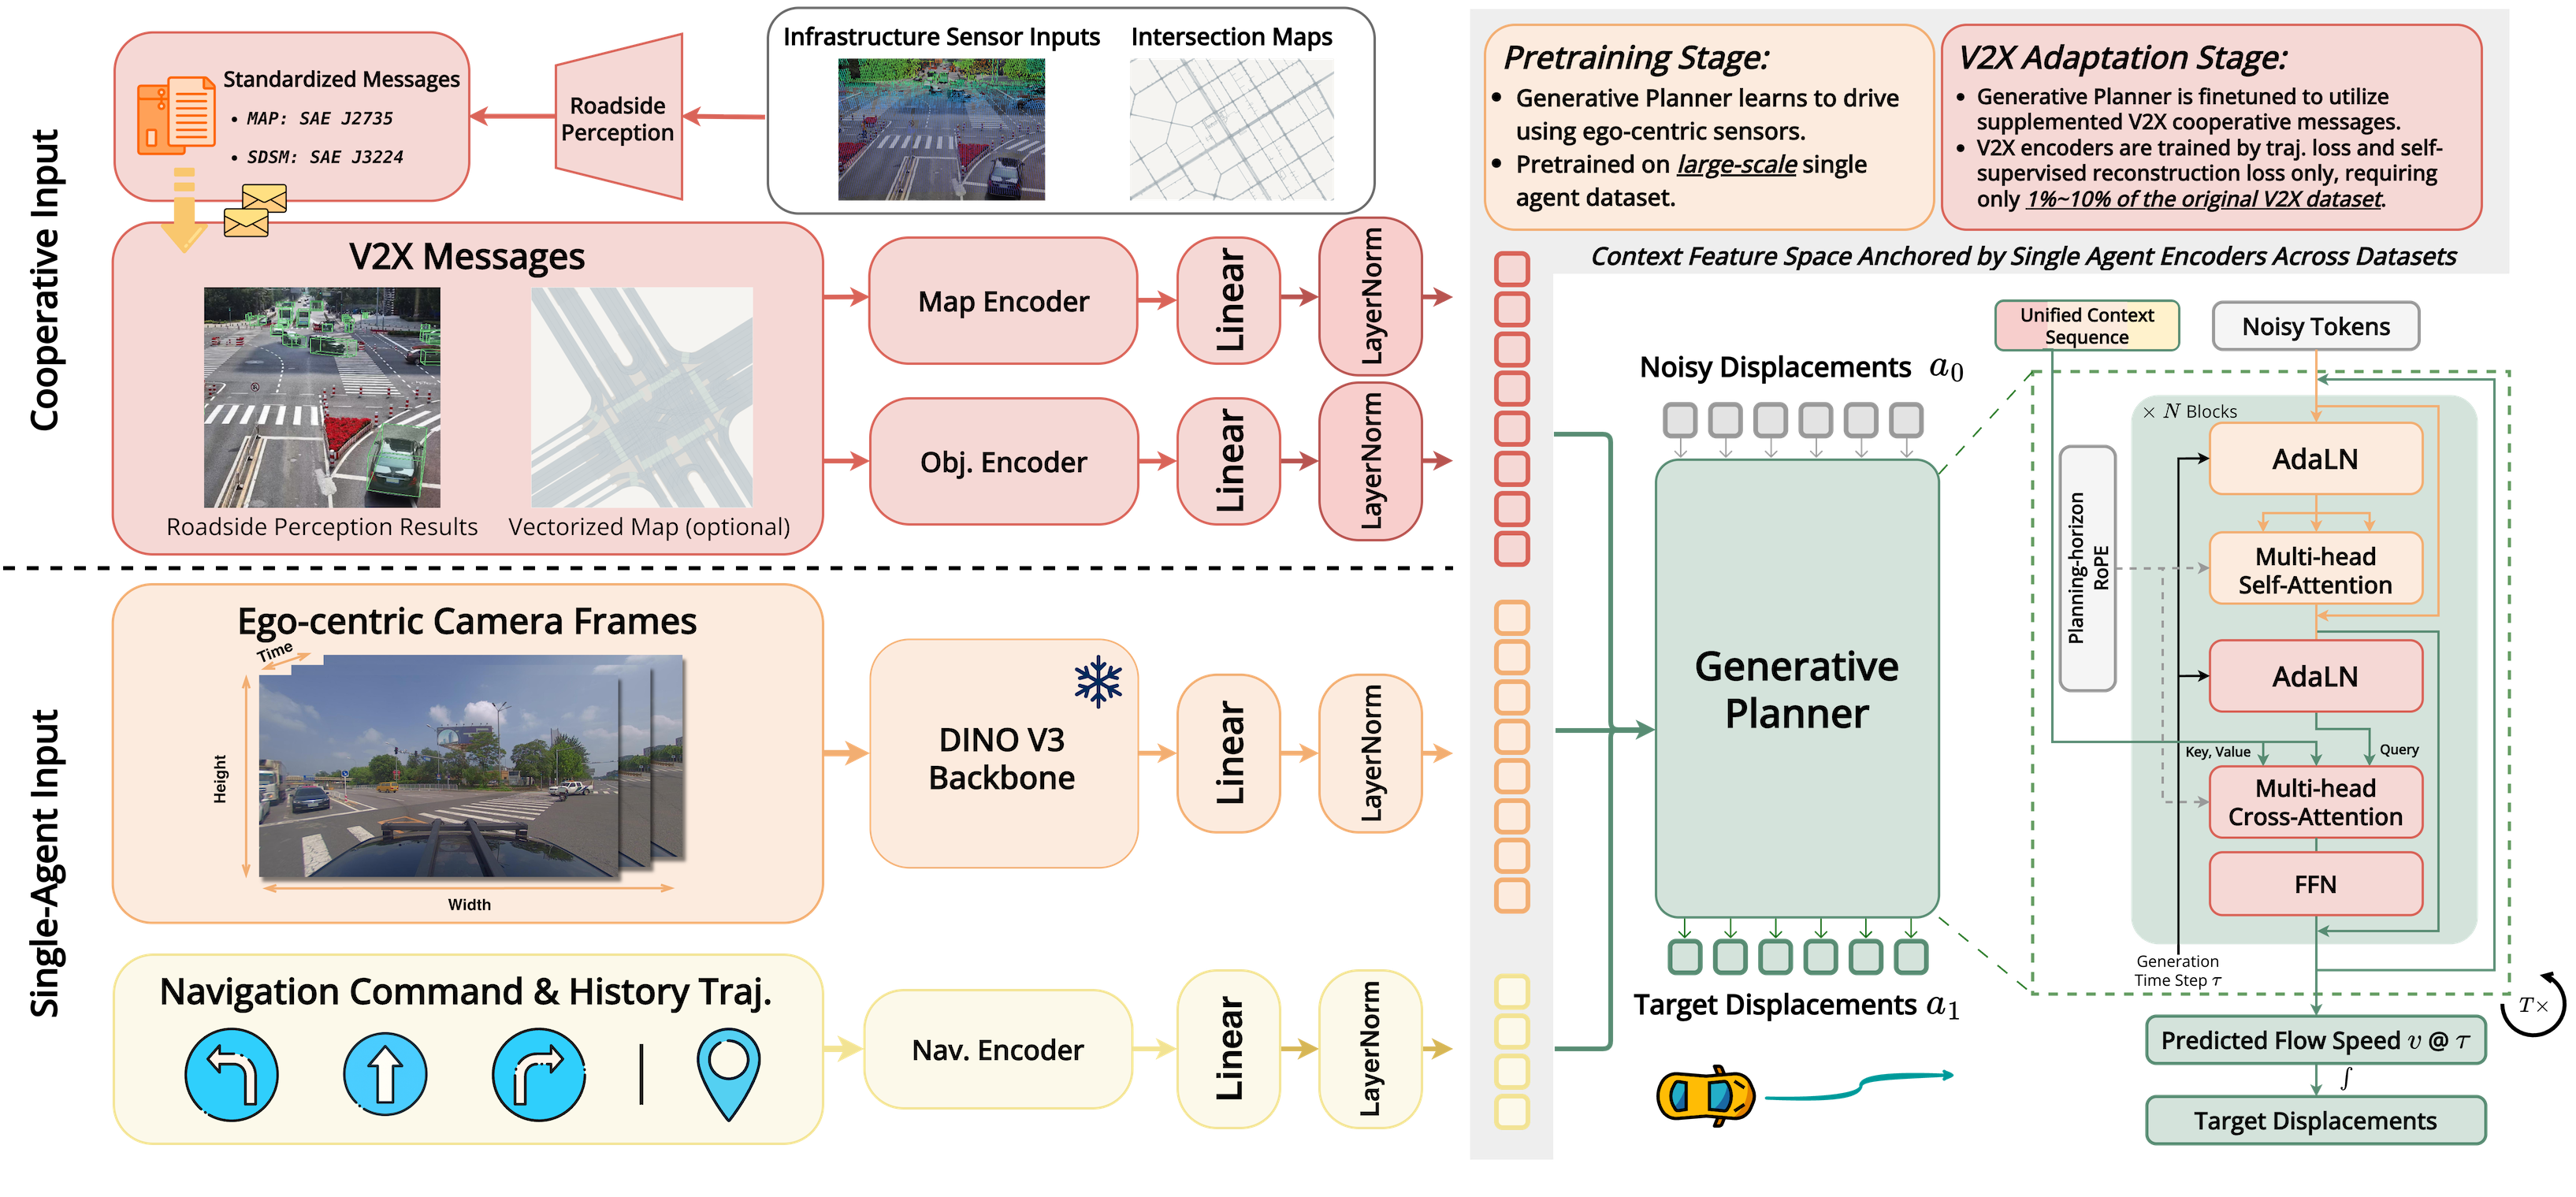
  3. OmniV2X: A Generative Foundation Planner for Efficient End-to-End Cooperative Driving
    Juntong Peng, Juanwu Lu, Yupeng Zhou, Can Cui, Yaobin Chen, and Ziran Wang
    In 2026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026
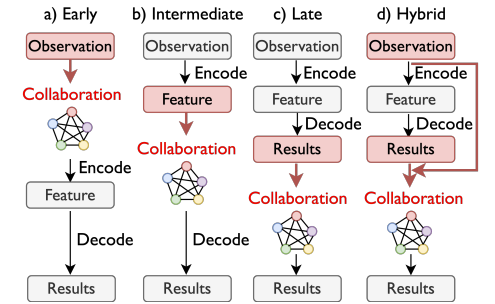
  4. Communication-Efficient Multi-Agent 3D Detection via Hybrid Collaboration
    Yue Hu, Juntong Peng, Yunqiao Yang, and Siheng Chen
    arXiv preprint arXiv:2508.07092, 2025
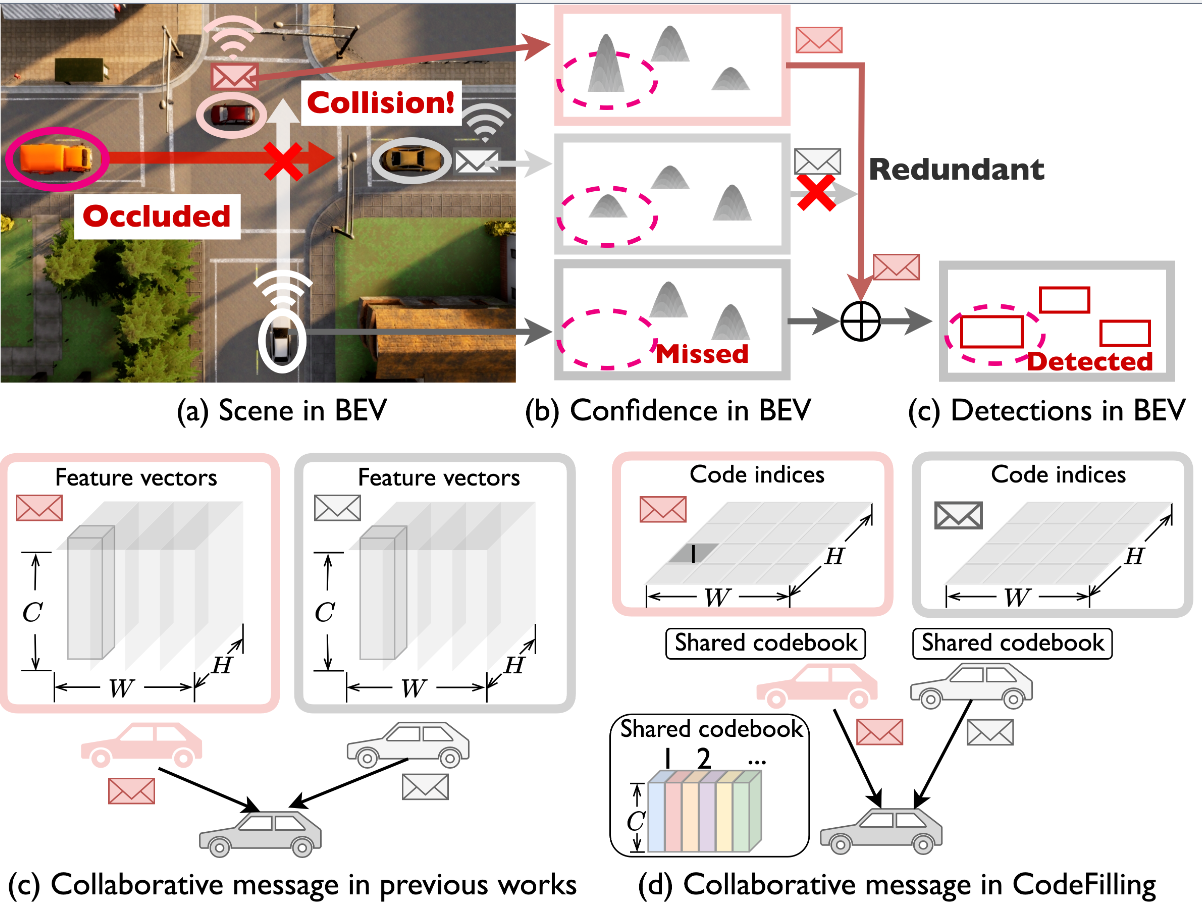
  5. Communication-Efficient Collaborative Perception via Information Filling with Codebook
    Yue Hu, Juntong Peng, Sifei Liu, Junhao Ge, Si Liu, and Siheng Chen
    In Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR), 2024
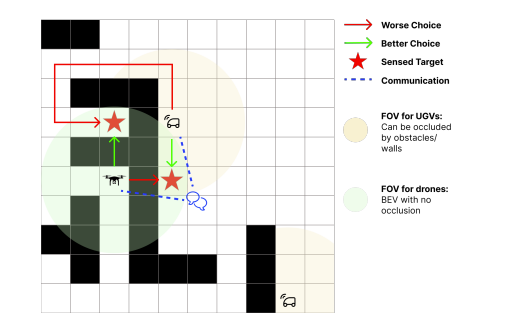
  6. Graph-Based Decentralized Task Allocation for Multi-Robot Target Localization
    Juntong Peng, Hrishikesh Viswanath, and Aniket Bera
    IEEE Robotics and Automation Letters, 2024
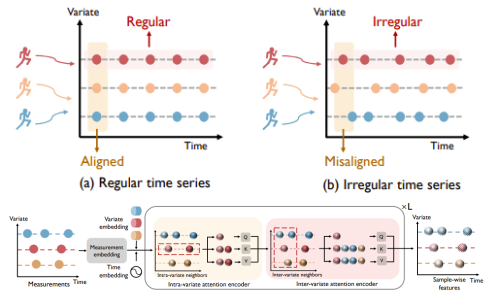
  7. Compatible Transformer for Irregularly Sampled Multivariate Time Series
    Yuxi Wei, Juntong Peng, Tong He, Chenxin Xu, Jian Zhang, Shirui Pan, and Siheng Chen
    In 2023 IEEE International Conference on Data Mining (ICDM), 2023